Mechanical shape control
Mechanisms that translate shared position and size settings into local surface motion, reducing individual module commands.
Robotics & mechanical engineering
PhD researcher
Worcester Polytechnic Institute
I work on reconfigurable soft robots, mechanical control of shape displays, and surfaces that can be reshaped and hold their form.
I focus on simplifying fabrication and assembly.
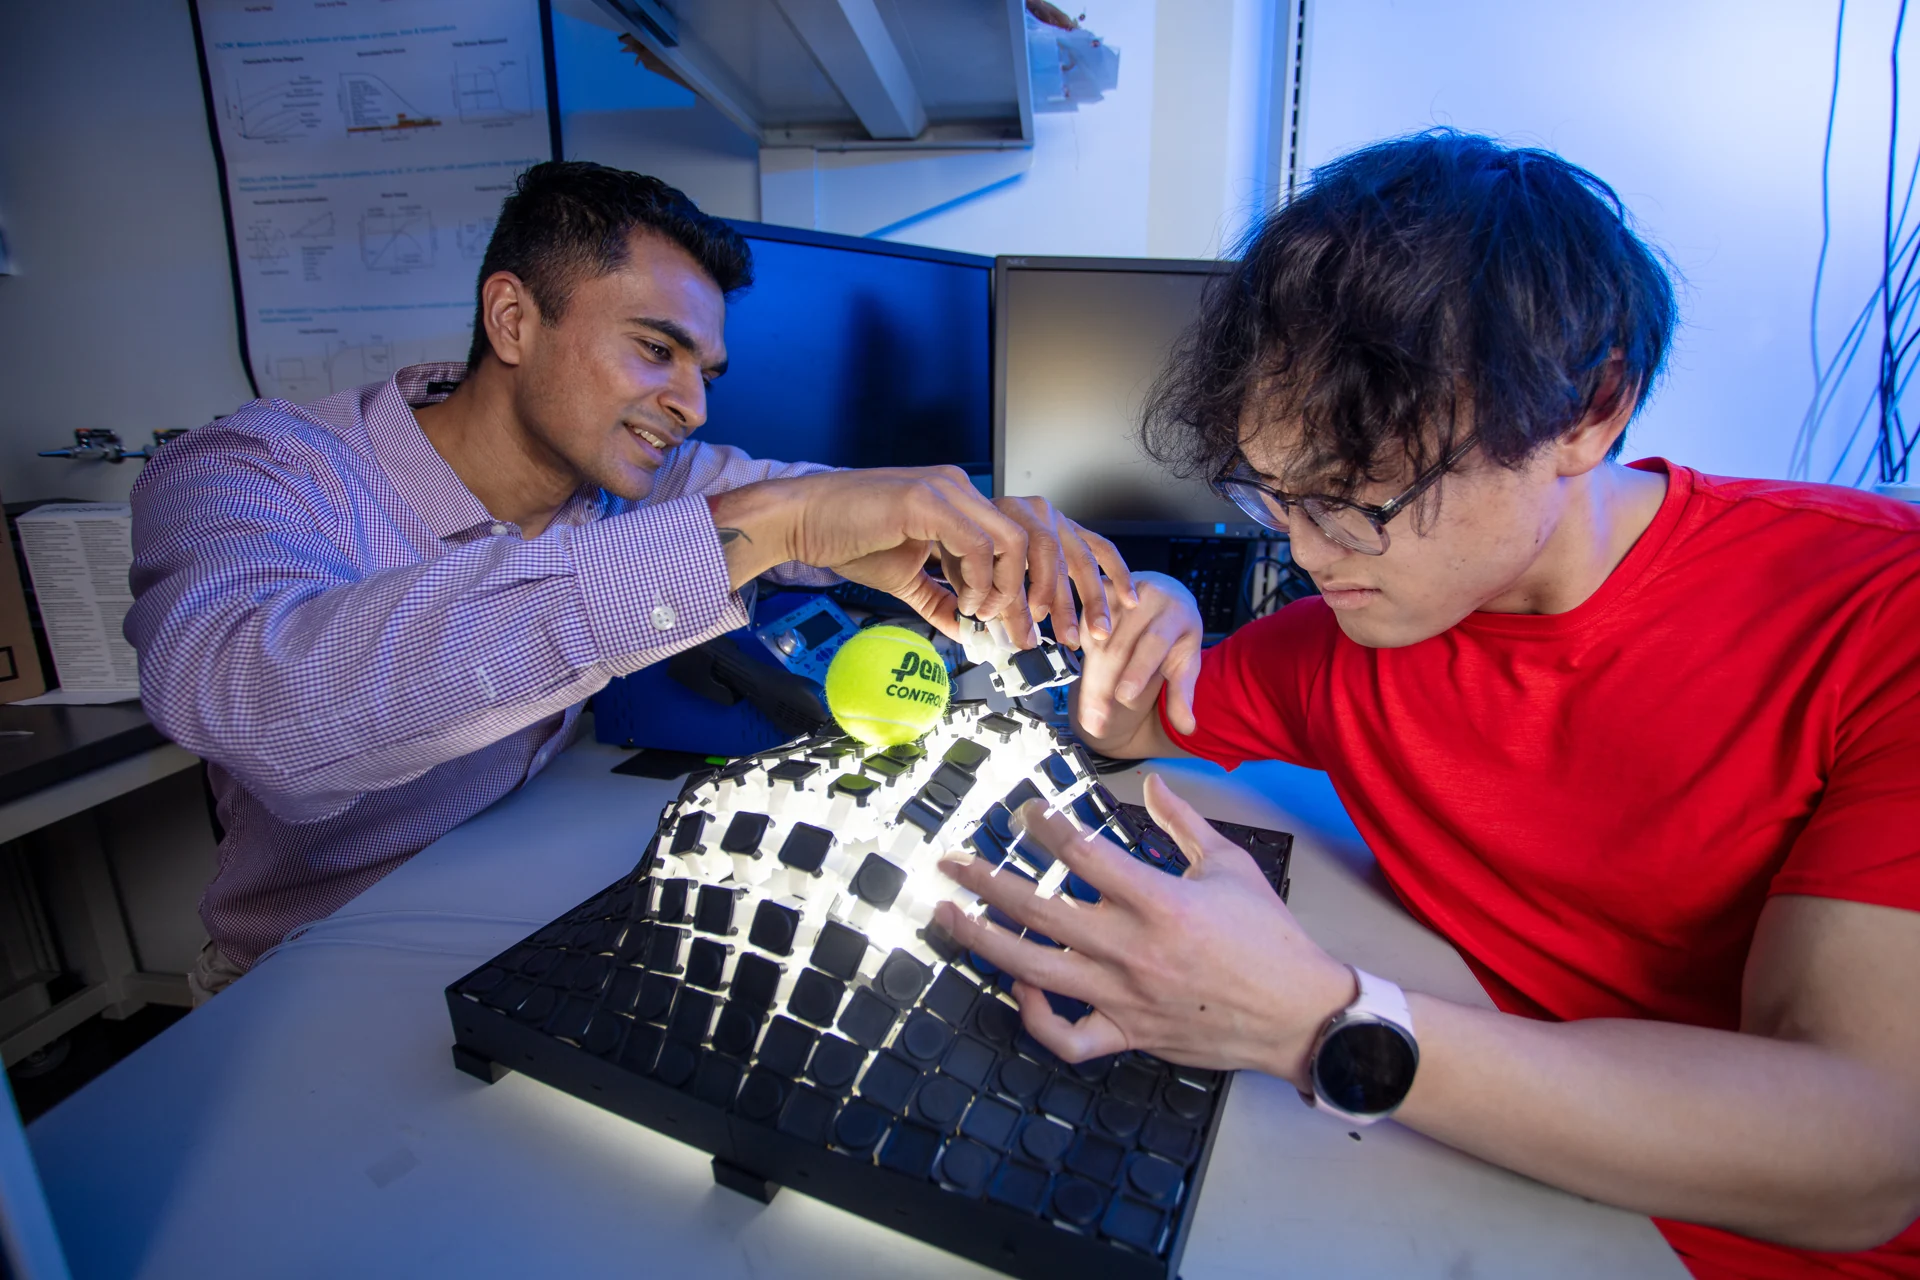
I developed printed cells that combine a pneumatic actuator and a compliant linkage in one part. The cells can be rearranged into morphing surfaces, continuum arms, crawlers, and rolling rings.
Project, demonstrations, and experimentsMechanisms that translate shared position and size settings into local surface motion, reducing individual module commands.
Connected sheets that can form and retain domes, flat tops, and curling waves, using simple fabrication methods.
Sandia National Laboratories
Analytical, multibody, and finite-element models of a ratcheting mechanism under shock and vibration.
View project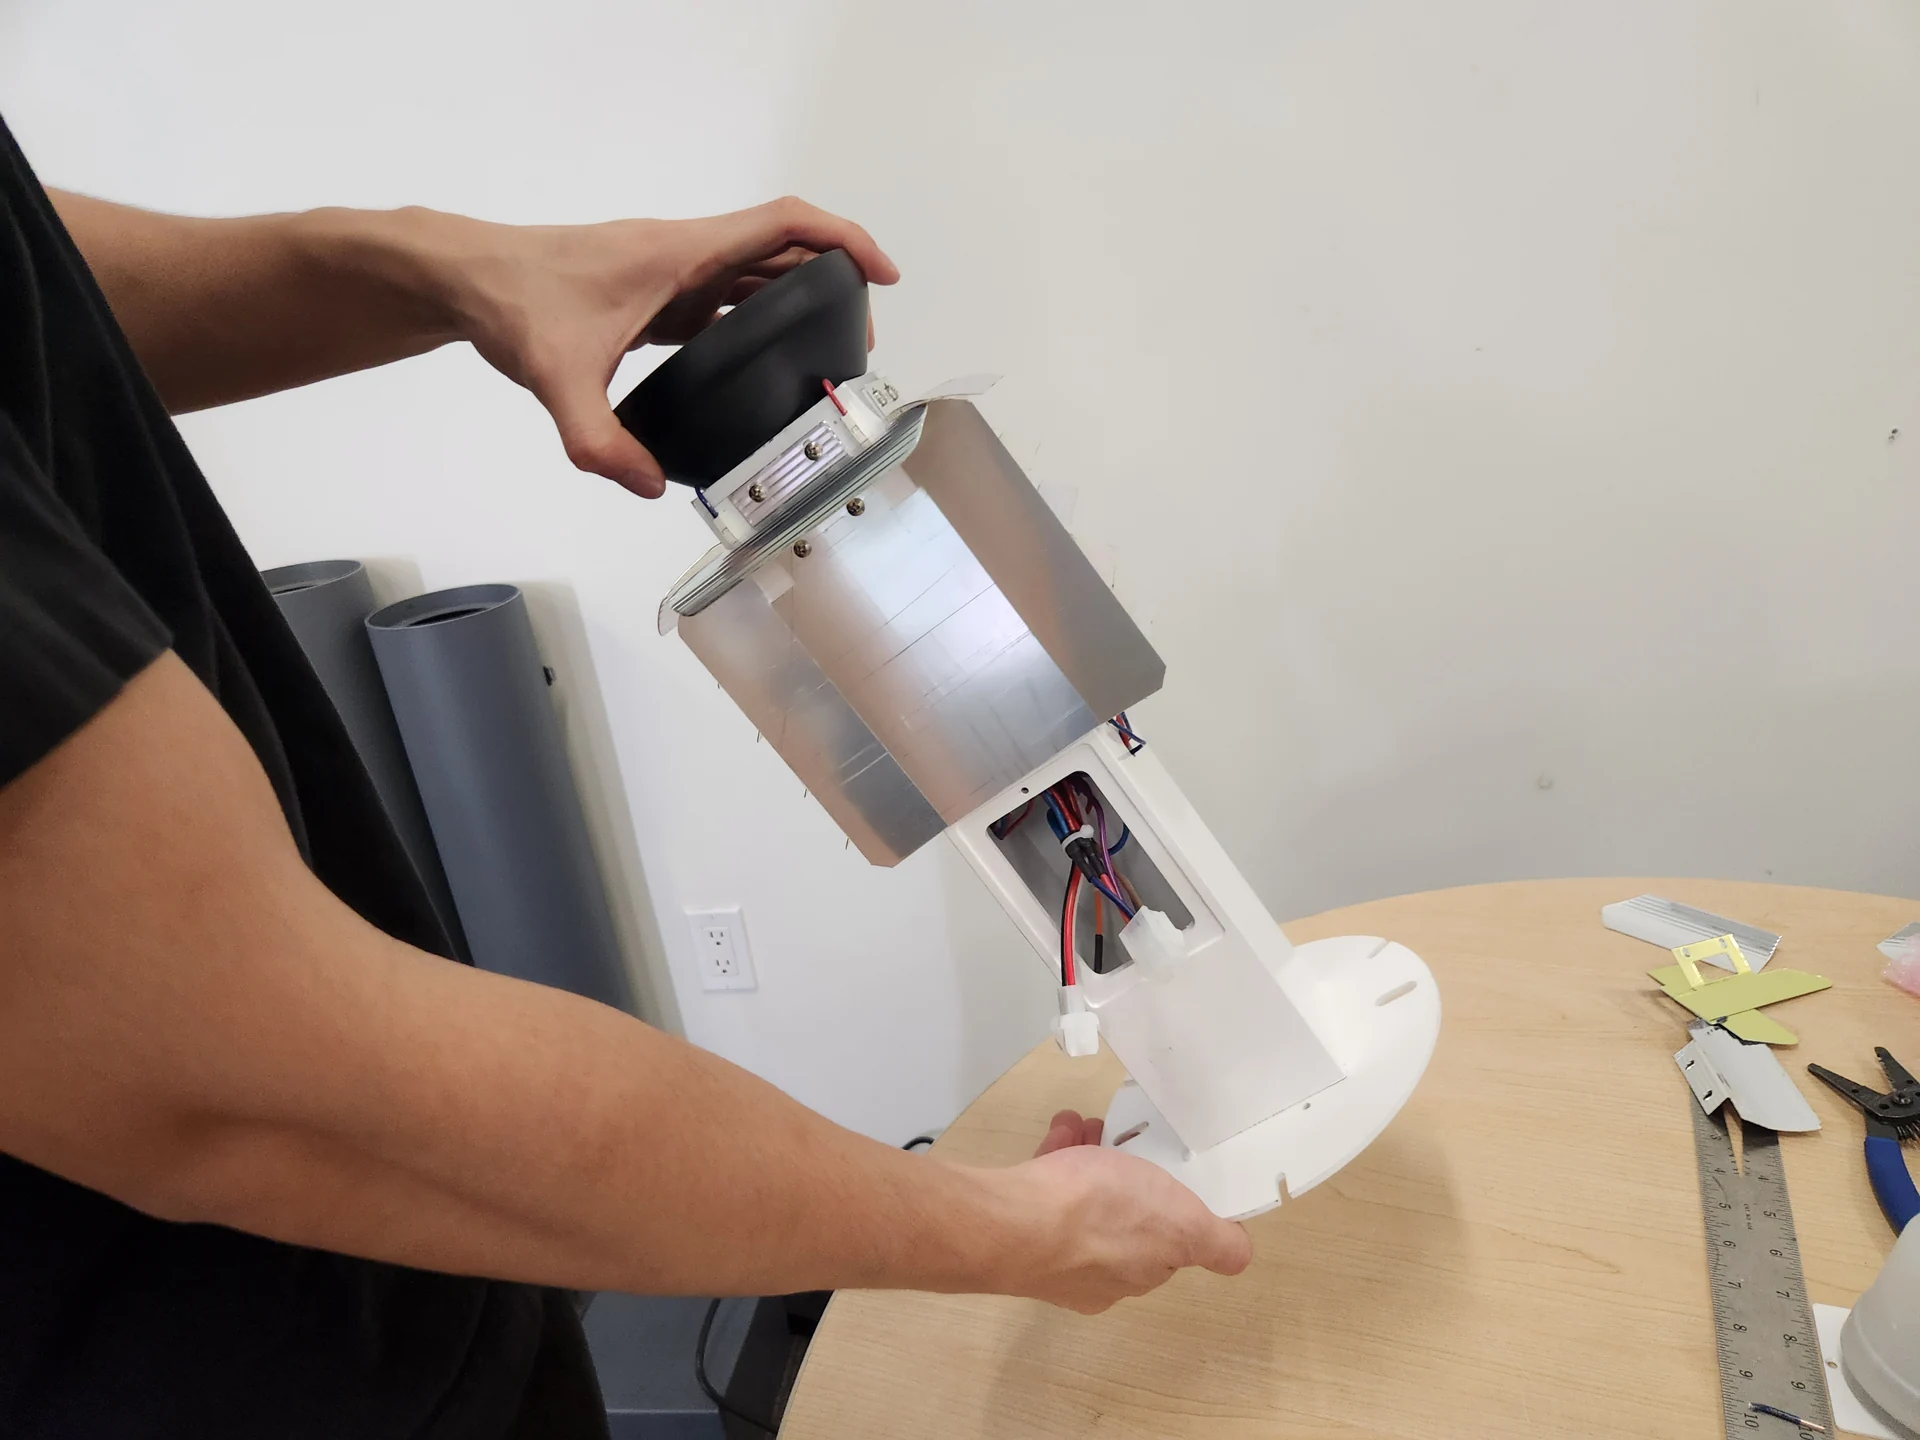
NLS Lighting
Retrofit clamps, gasket interfaces, mounting hardware, and water-ingress testing.
View project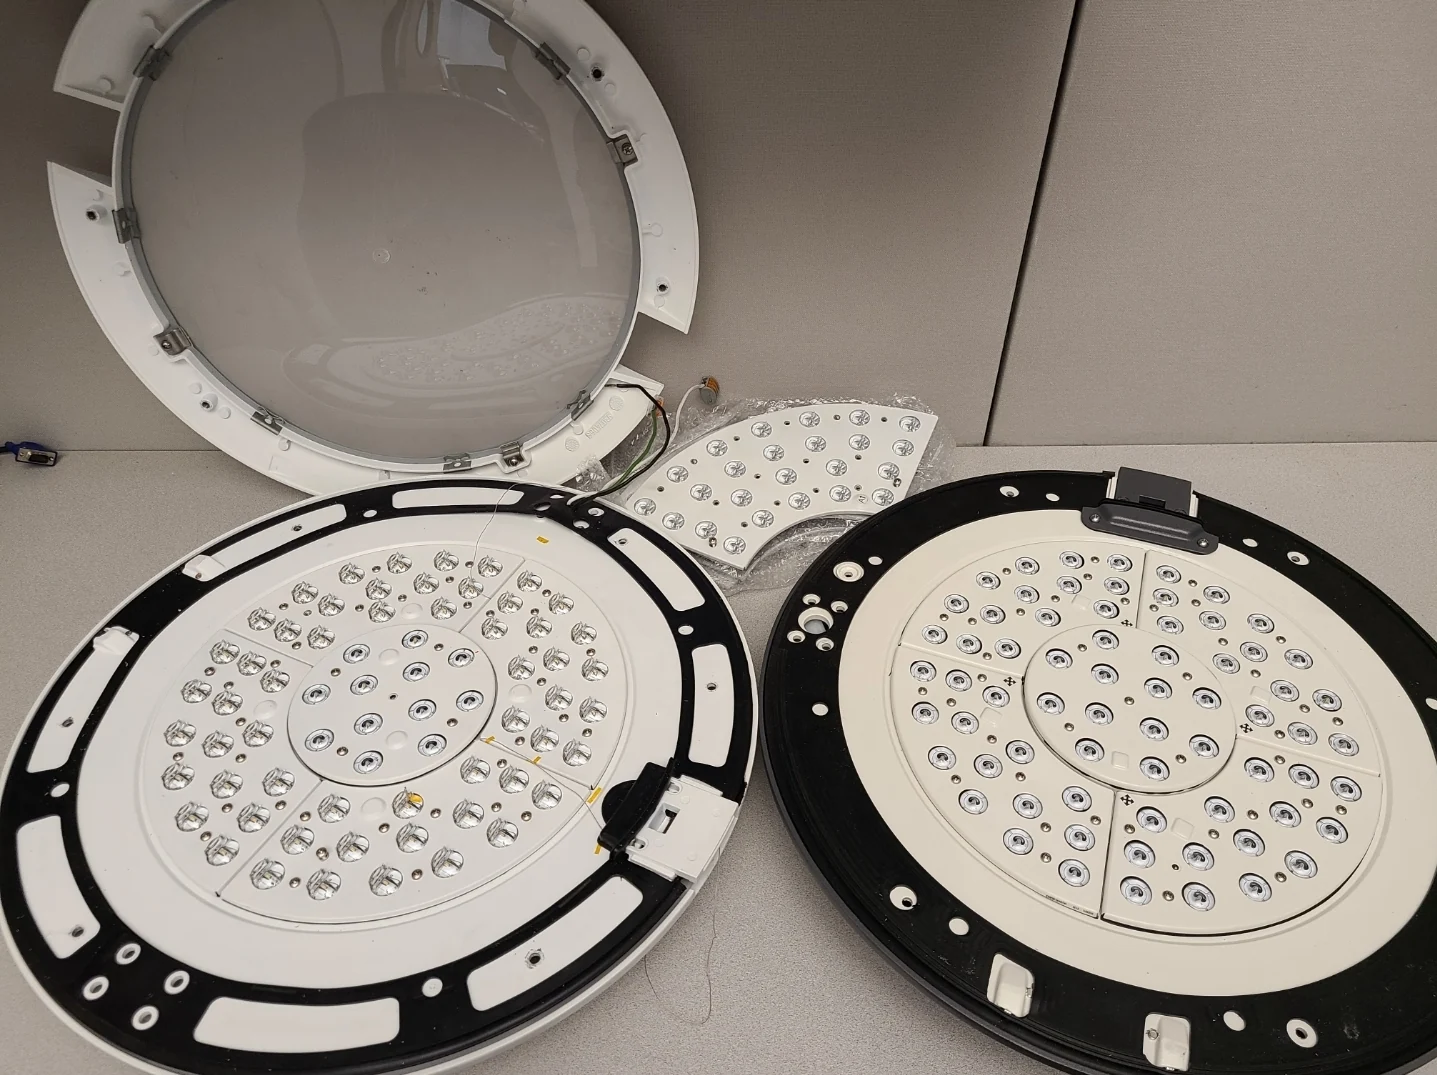
Hubbell
Fixture assembly, impact testing, finite-element analysis, and certification support.
View projectNASA L’SPACE NPWEE · 2025–2026
Mechanical design and prototyping for Project SELENE, a team developing robotics for extreme and remote environments.
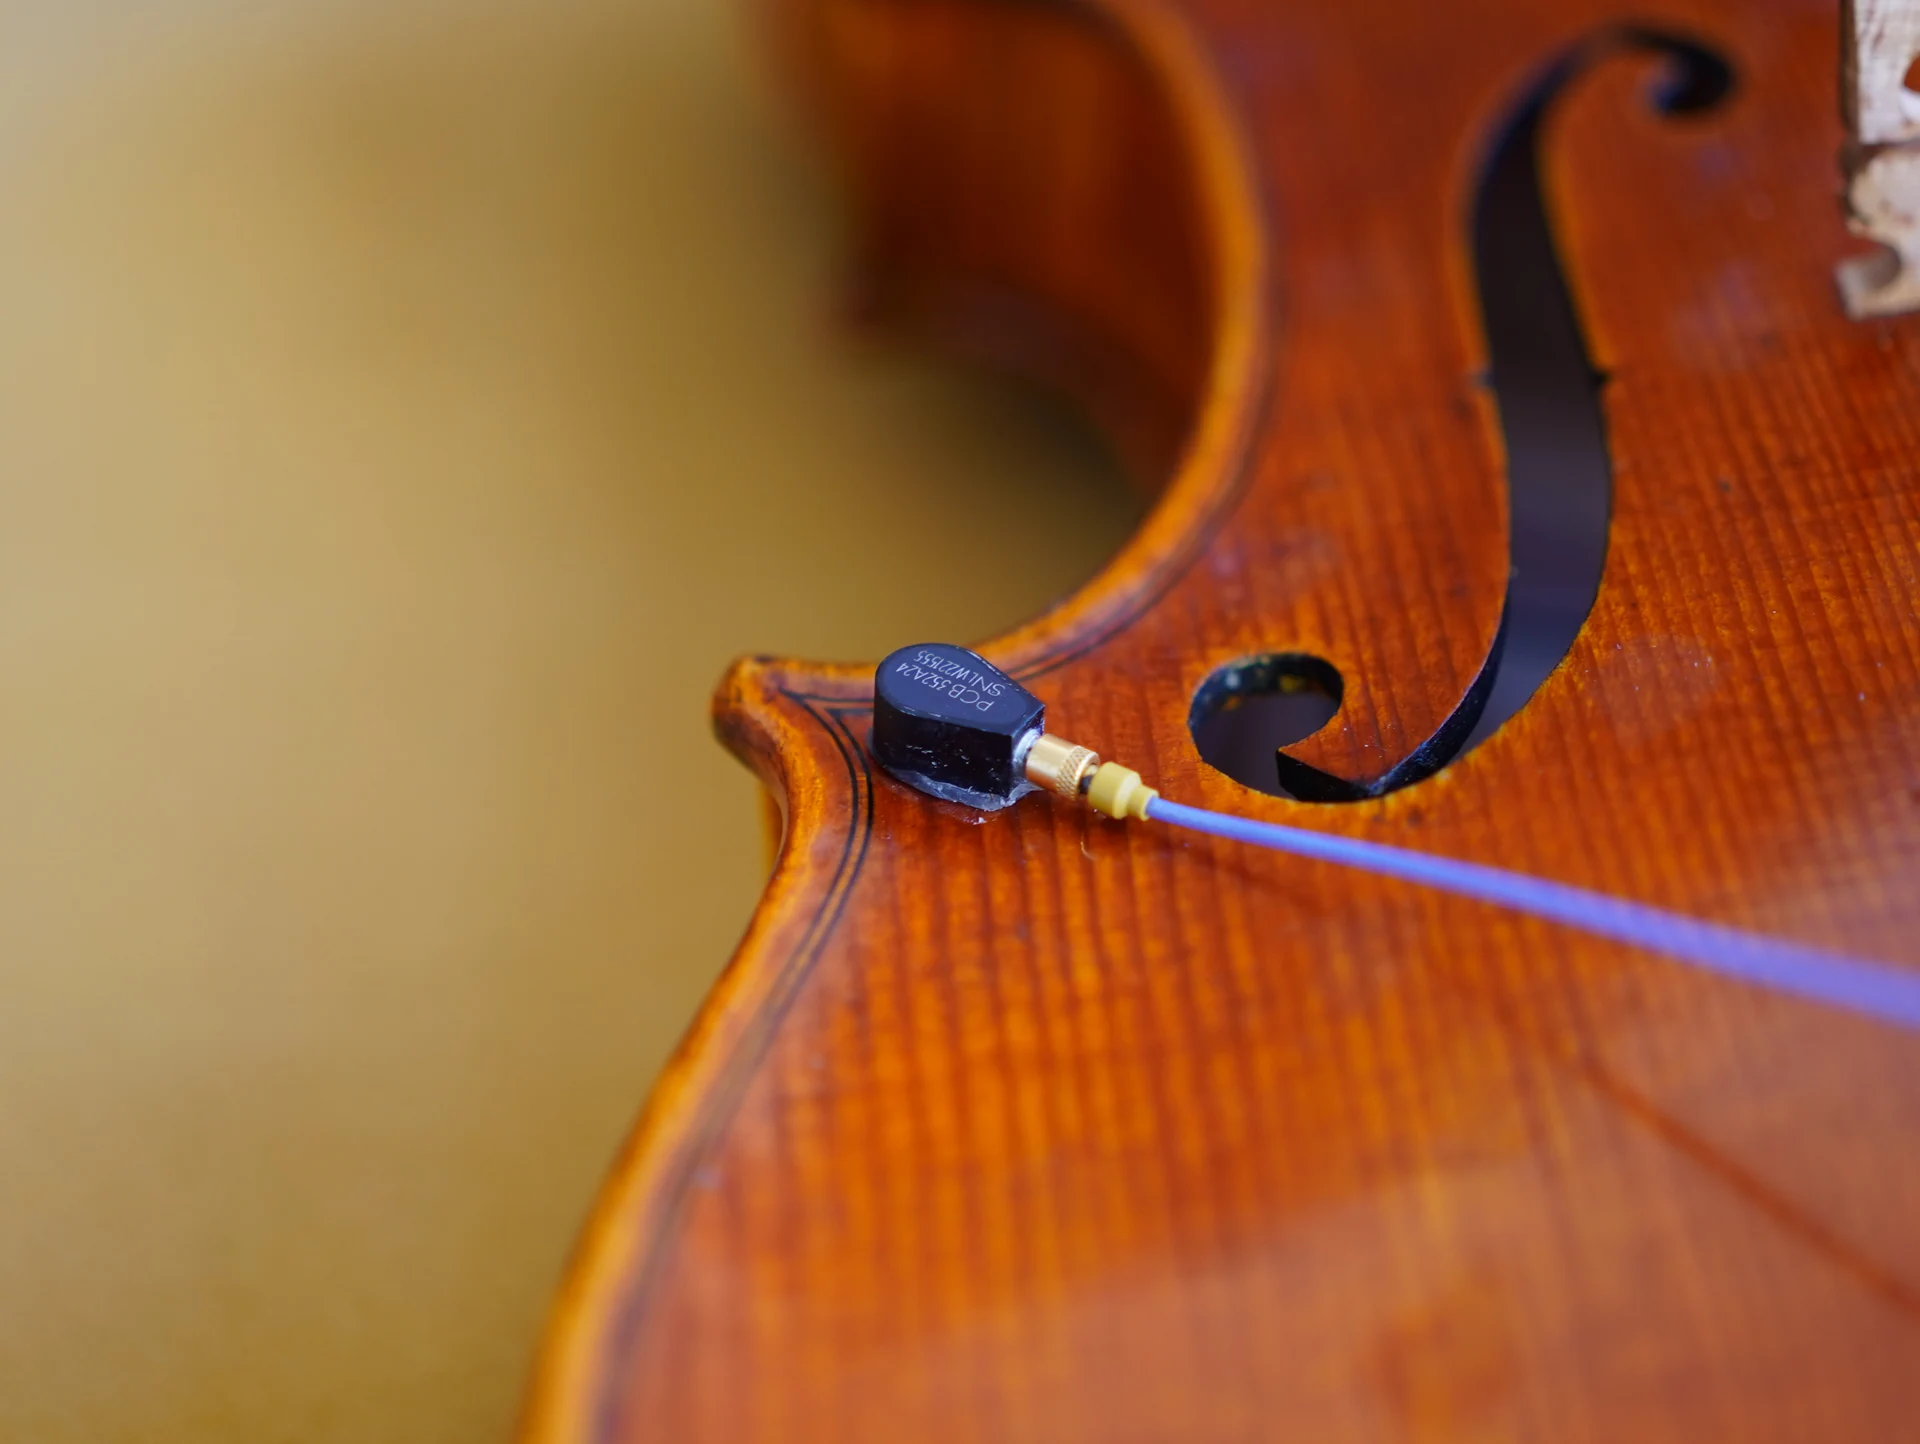
CSU Long Beach · MS thesis
Experimental comparison of two violins using accelerometers, microphones, and controlled excitation.
View project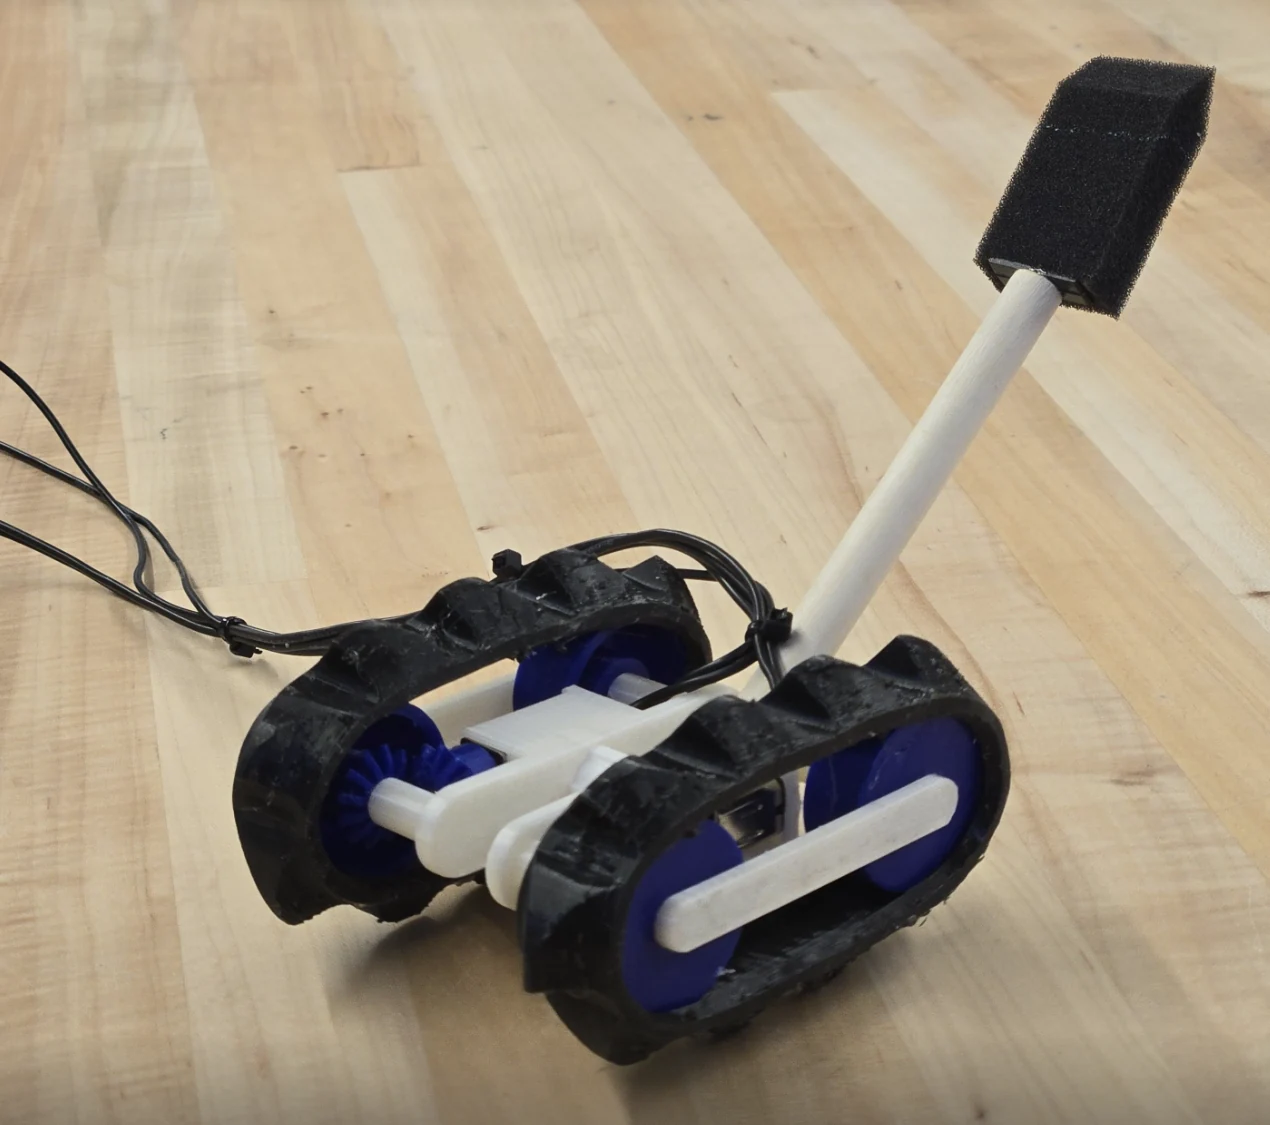
WPI · Team project
Compliant chassis connections, flexible treads, and obstacle and ramp tests.
View project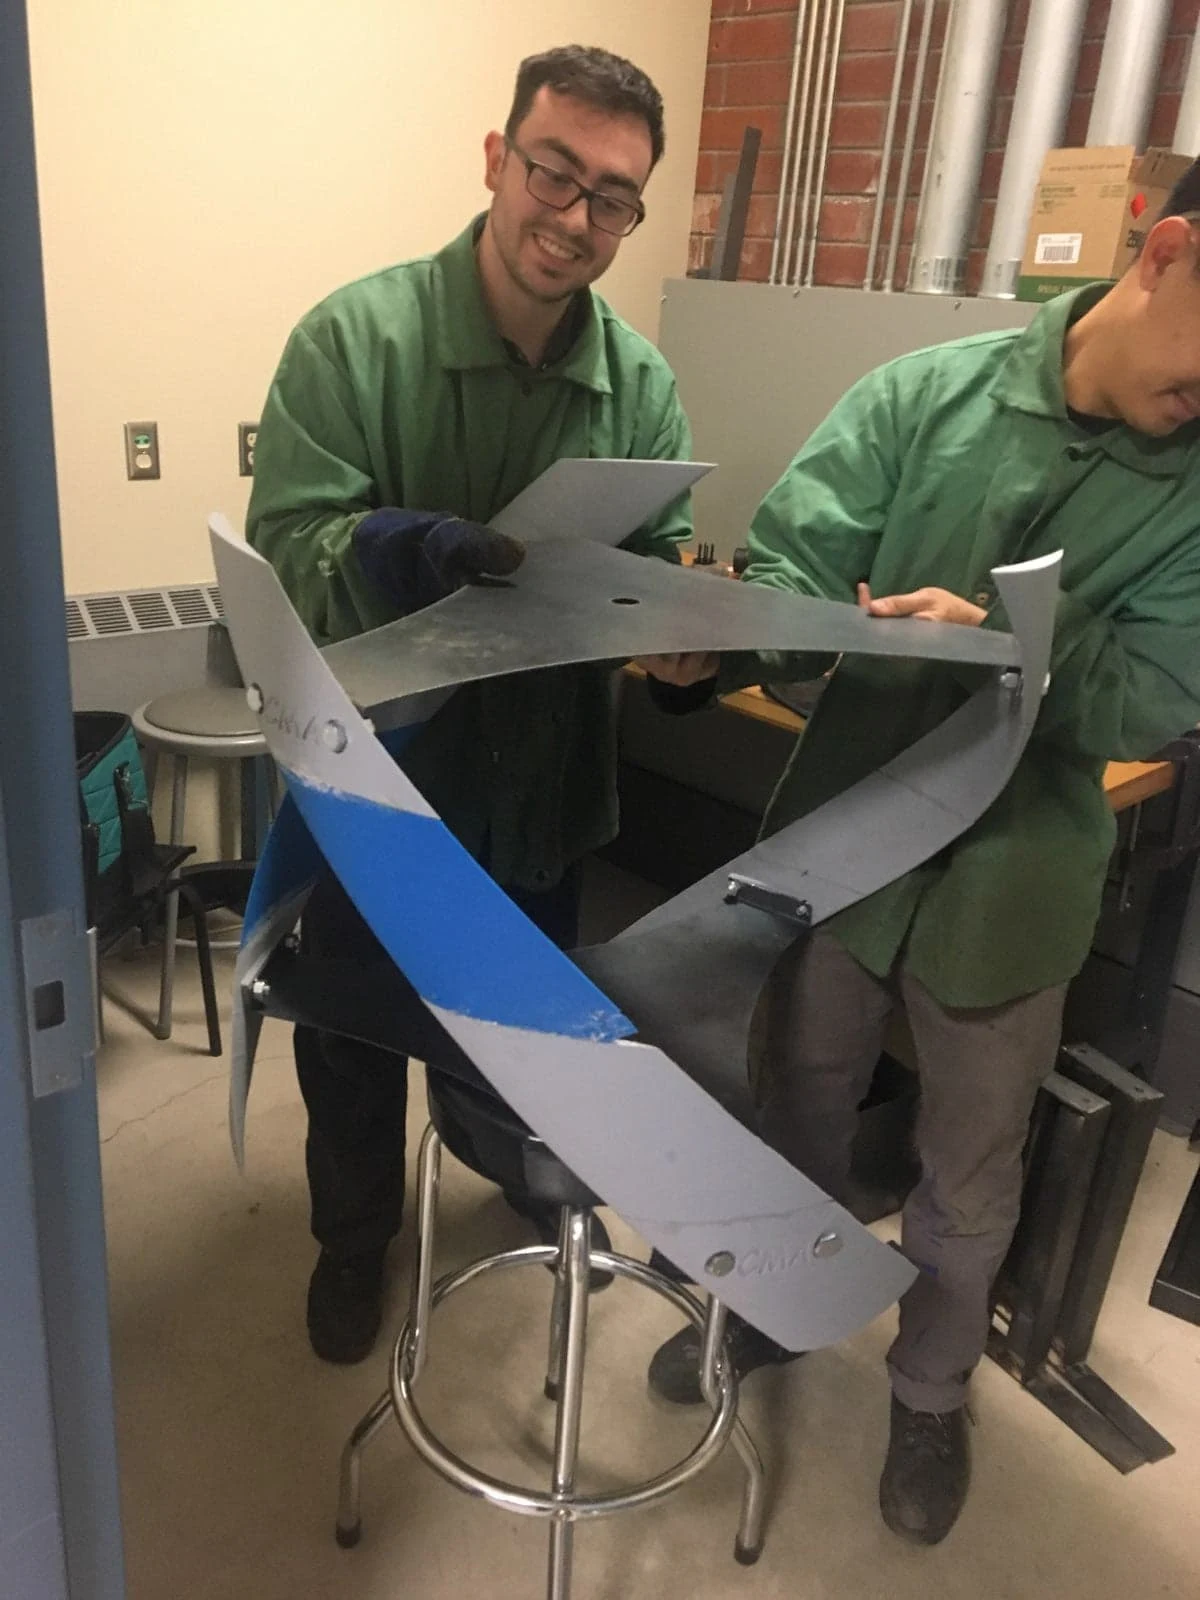
Cal Maritime · Senior design
Printed blade sections, composite reinforcement, generator characterization, and water tests.
View projectWPI · Research Assistant · 2023
Fabrication, assembly, kinematic checks, and build documentation.