My work at Sandia
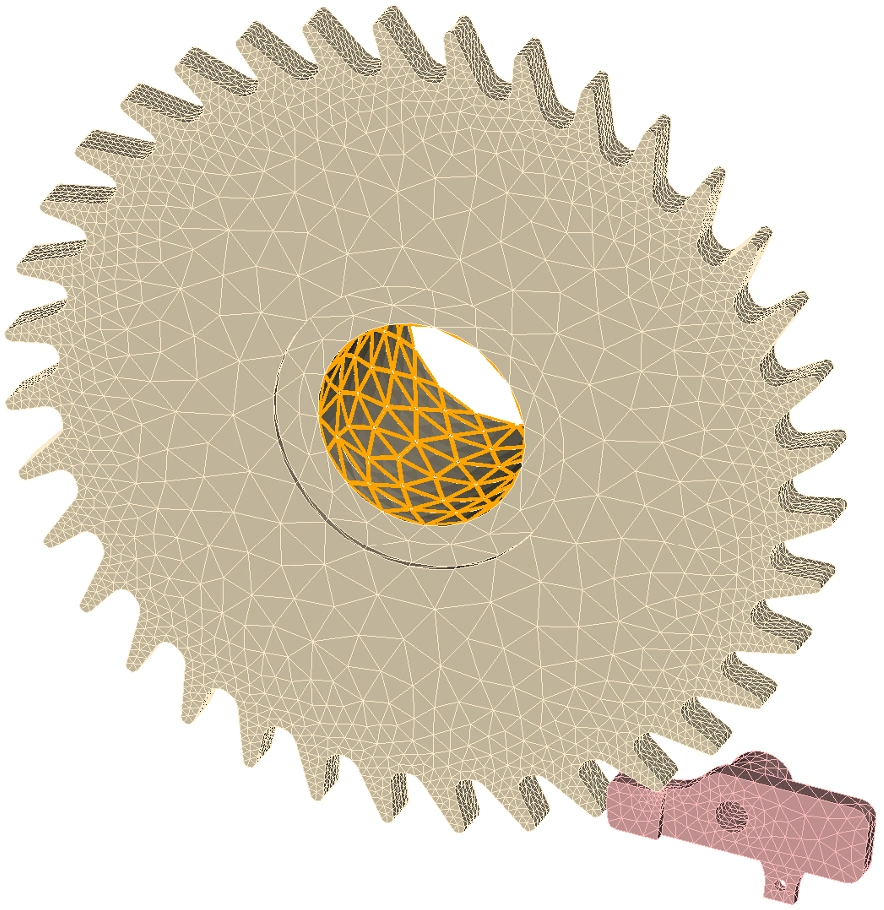
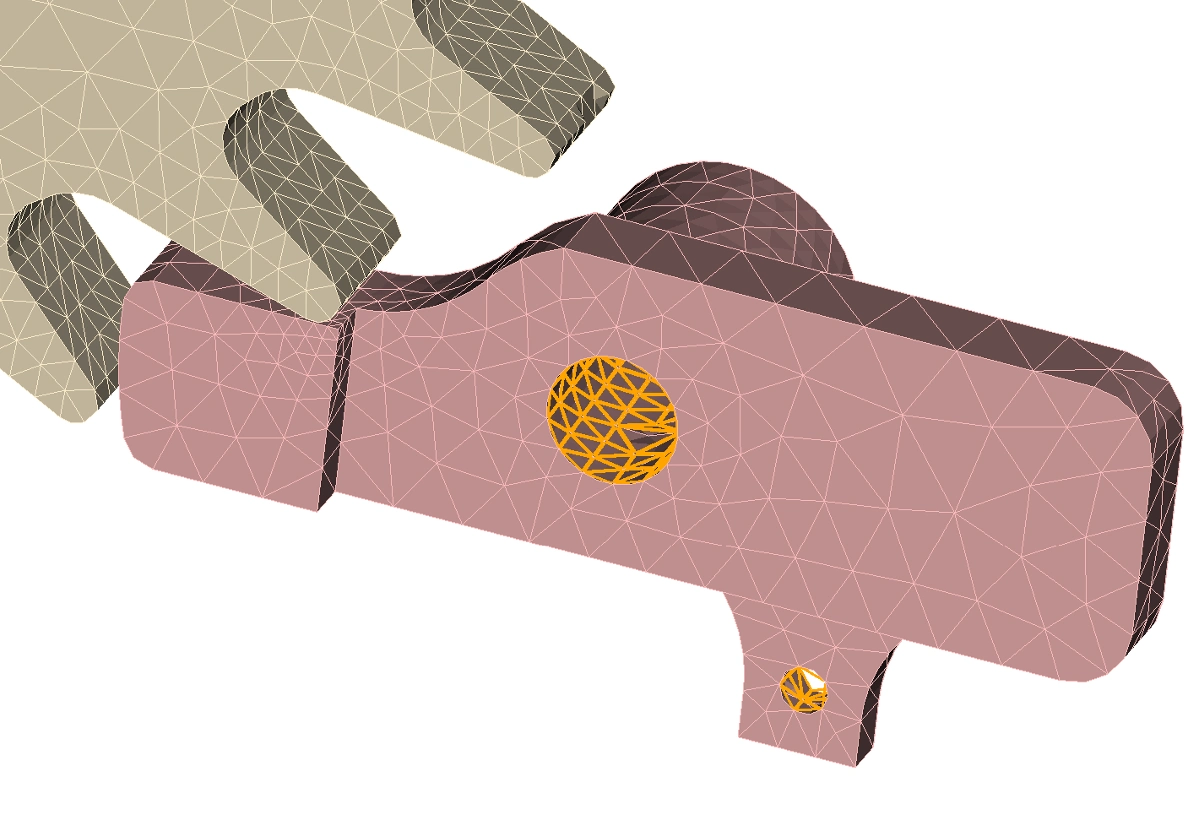
My primary focus in the NOMAD internship was the pawl-and-gear interaction in an electromechanical ratcheting mechanism. I worked on the idealized model and finite-element study, tracking how the hold pawl rotated as the ratchet wheel moved beneath it.
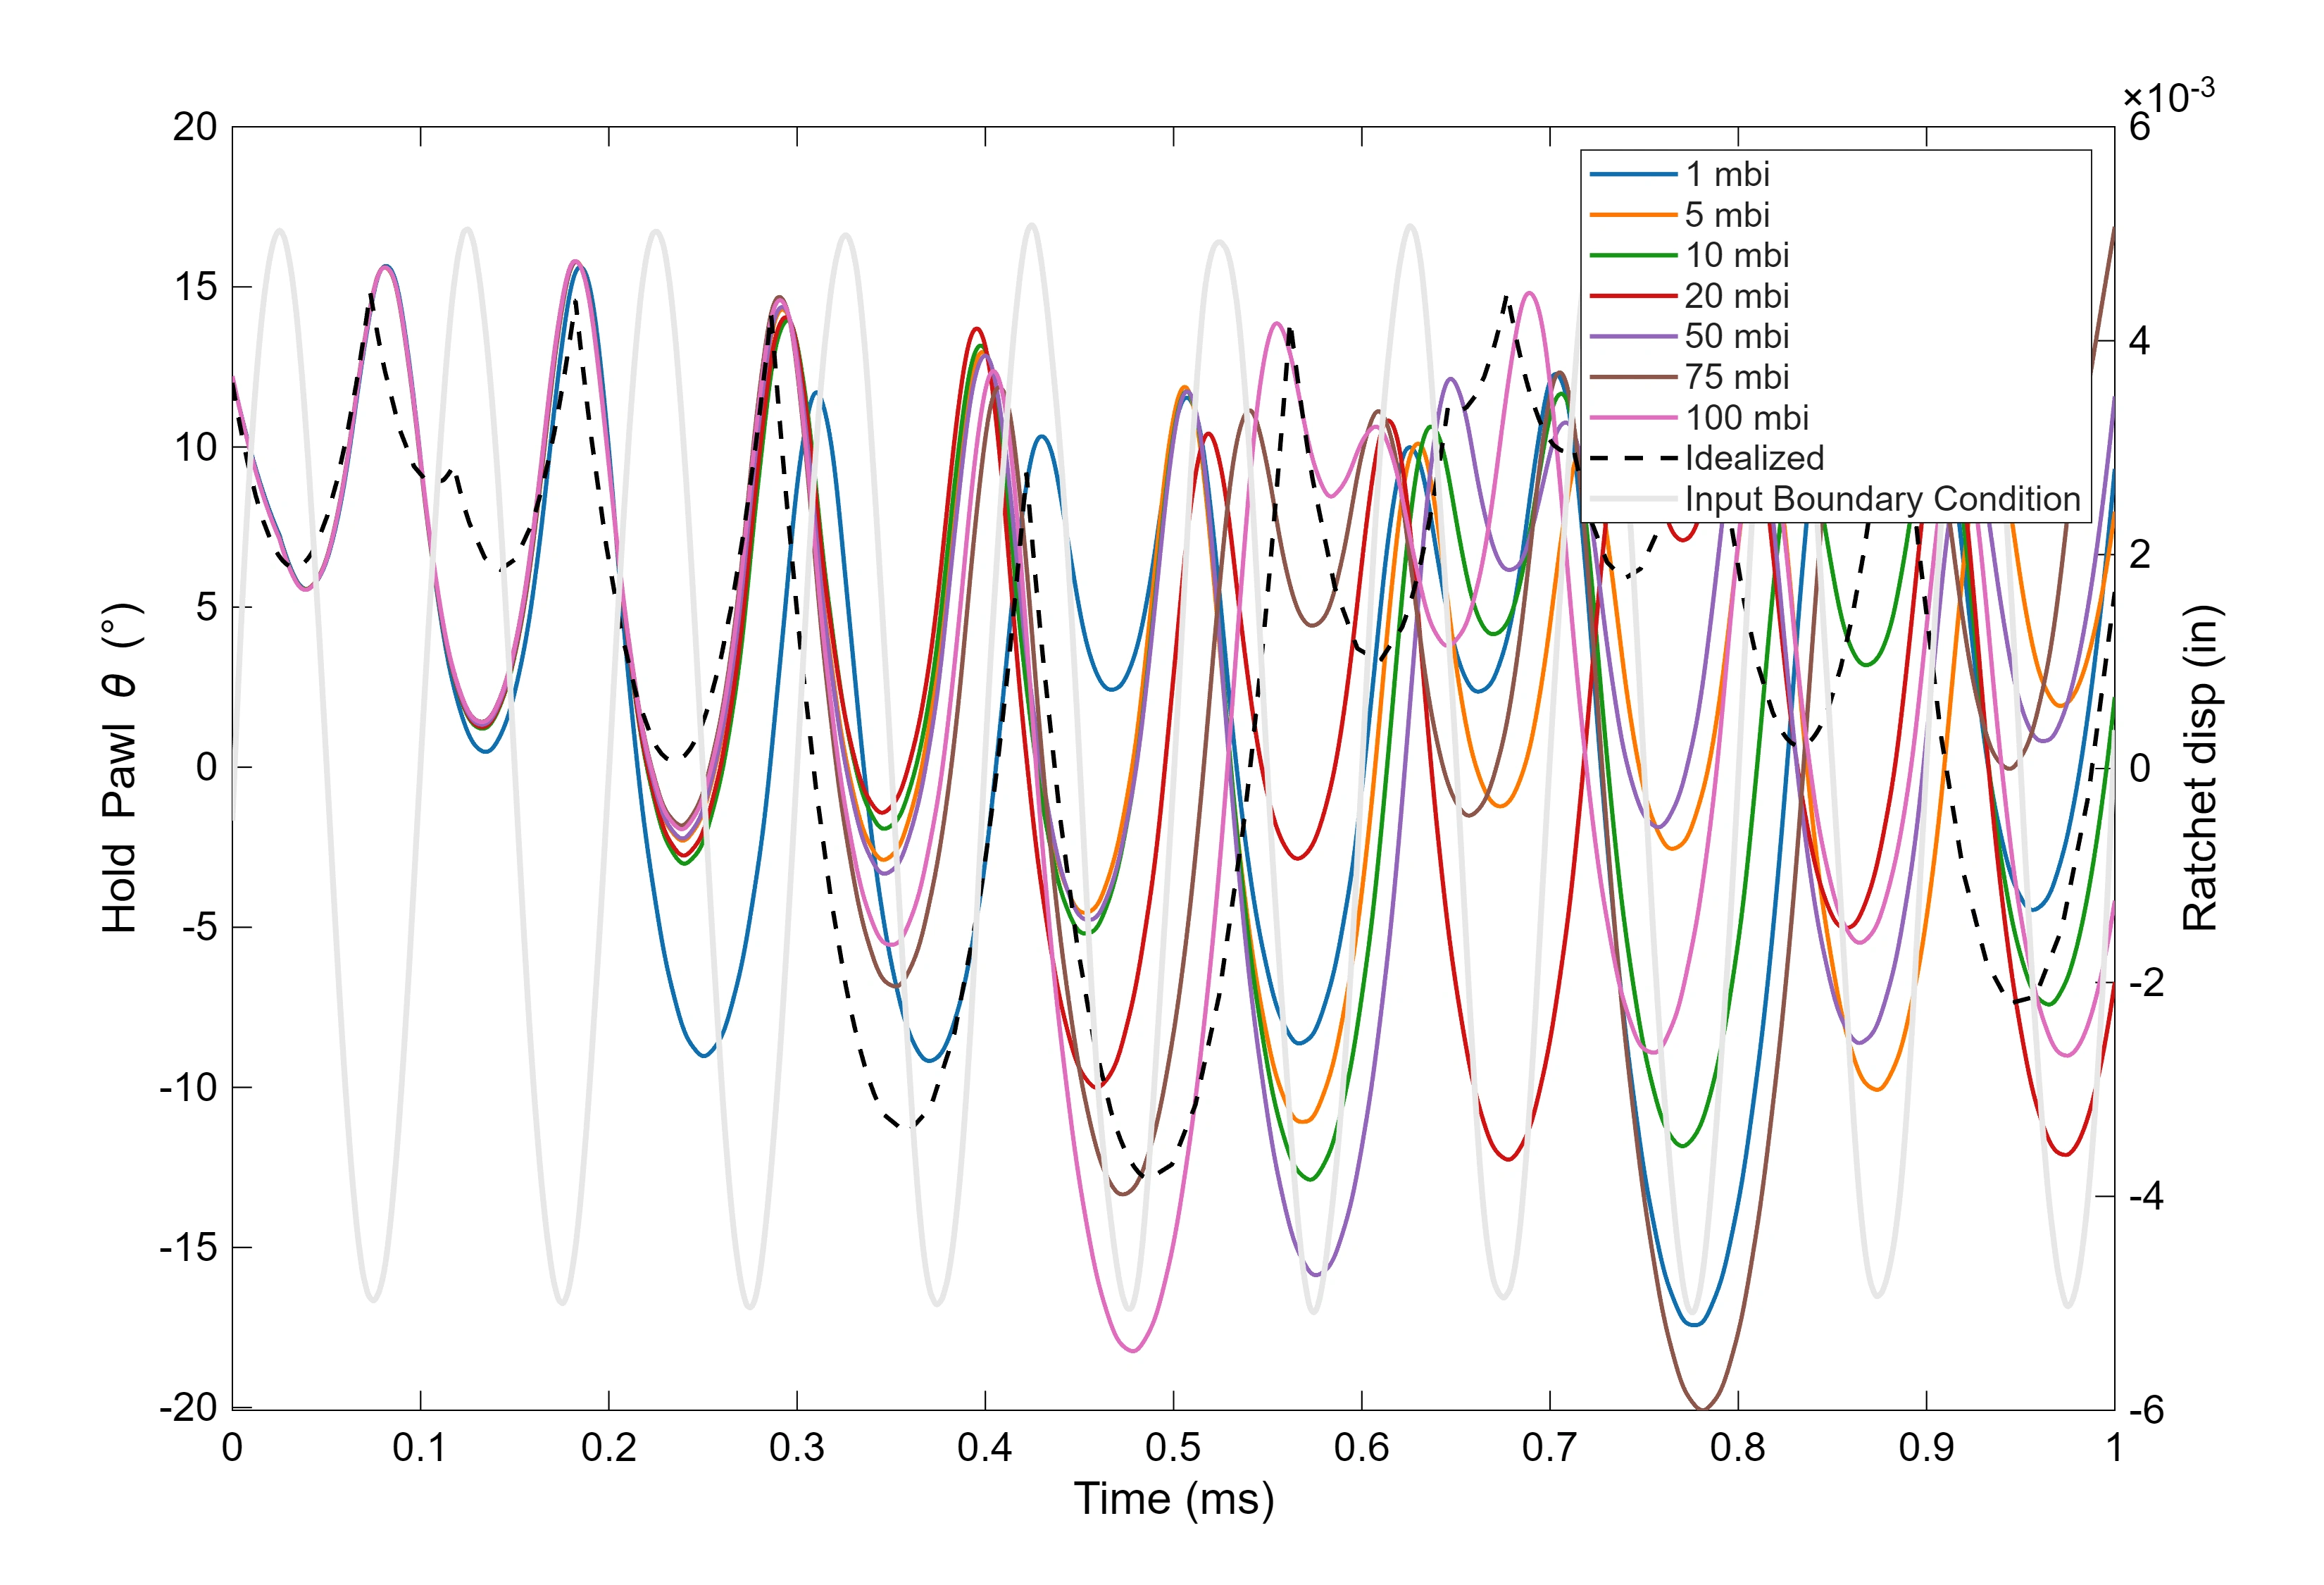
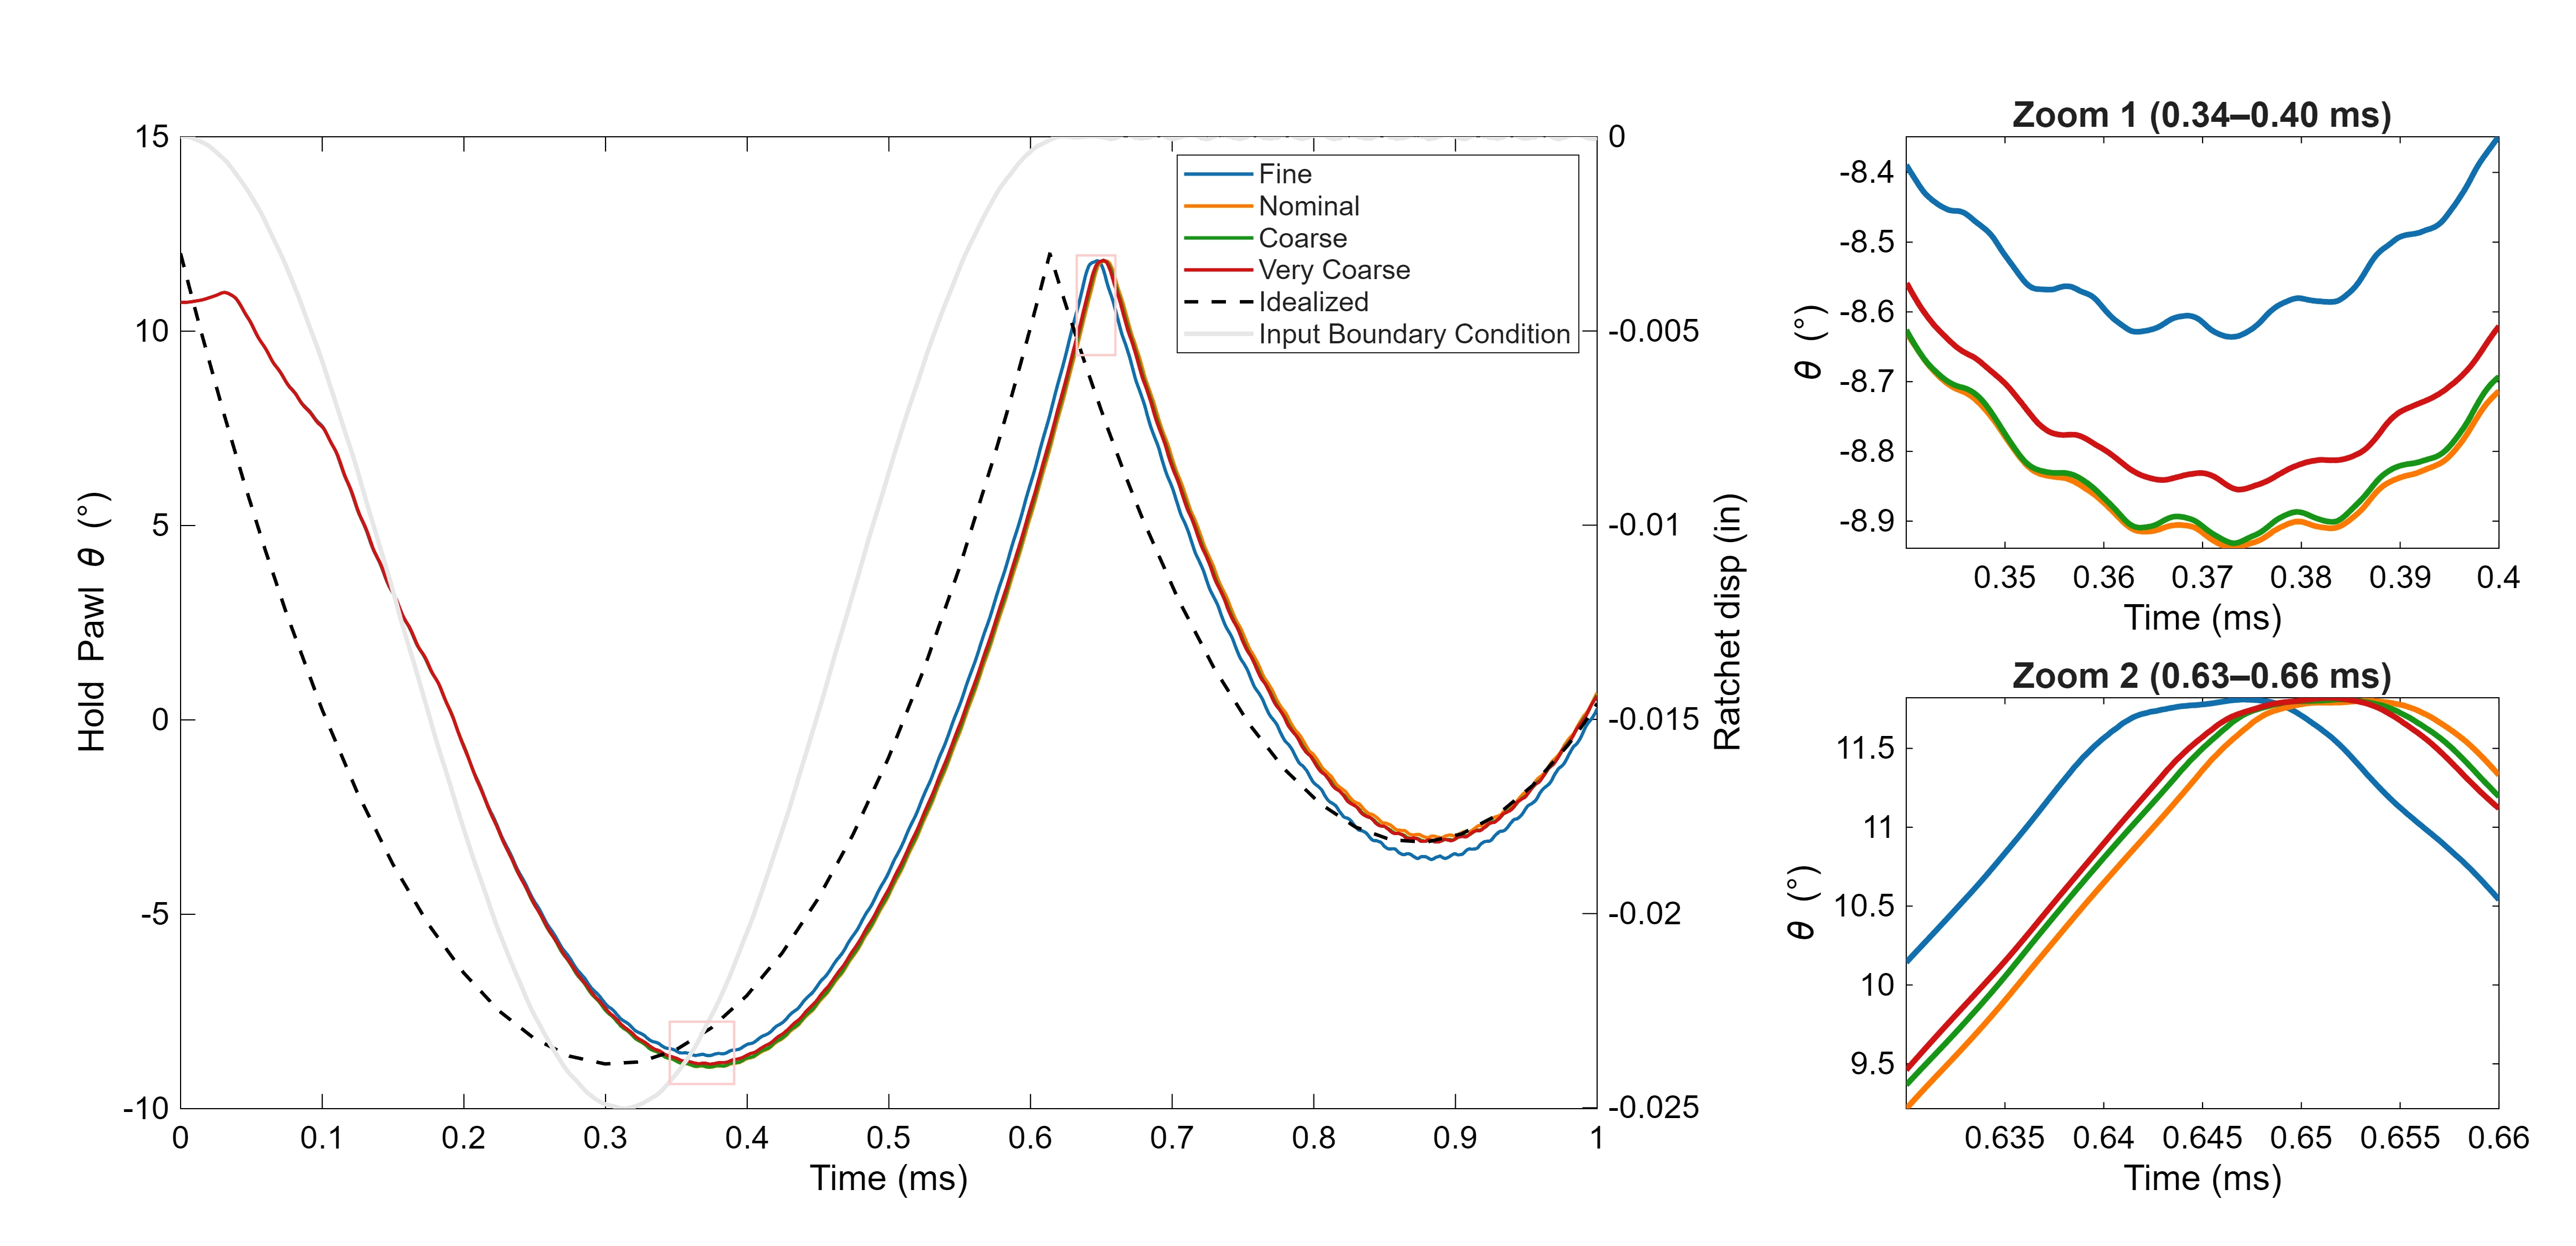
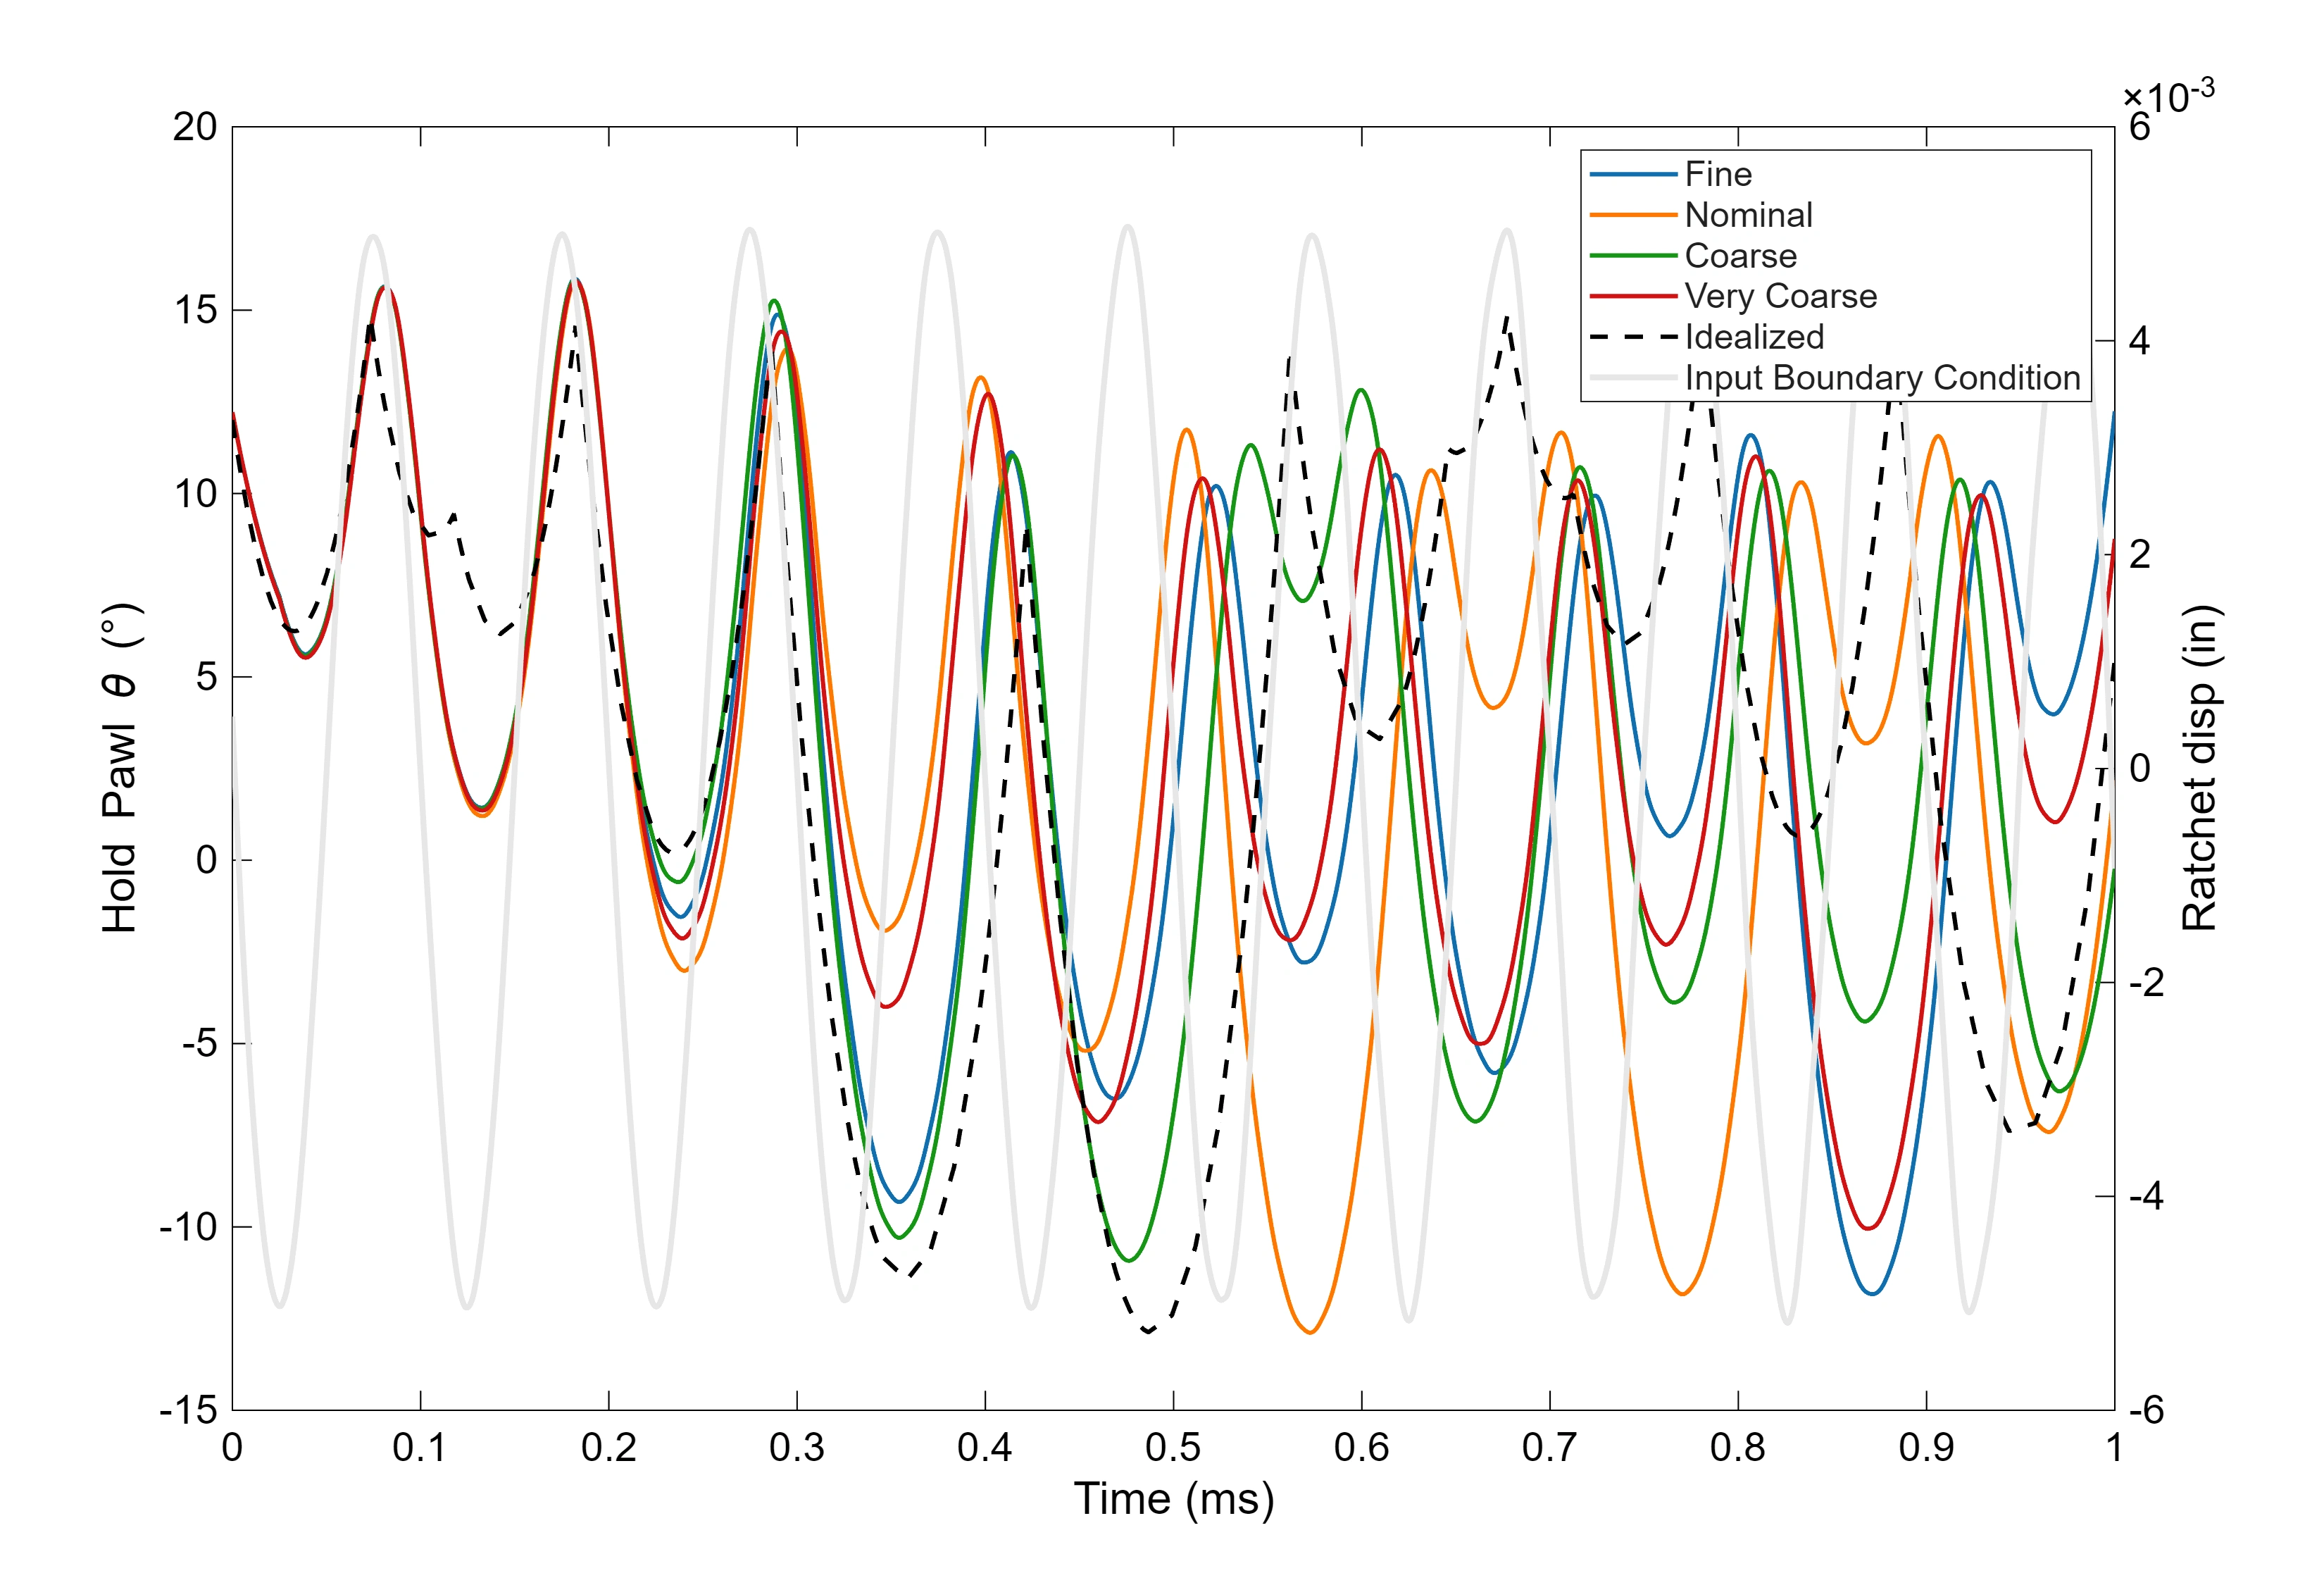
The central question was whether changes in the predicted motion came from the mechanism’s dynamics or from numerical choices in the simulation. I examined the pawl’s rotation history under shock and sustained vibration, comparing solver iterations, mesh density, and processor count.
Modeling the interaction
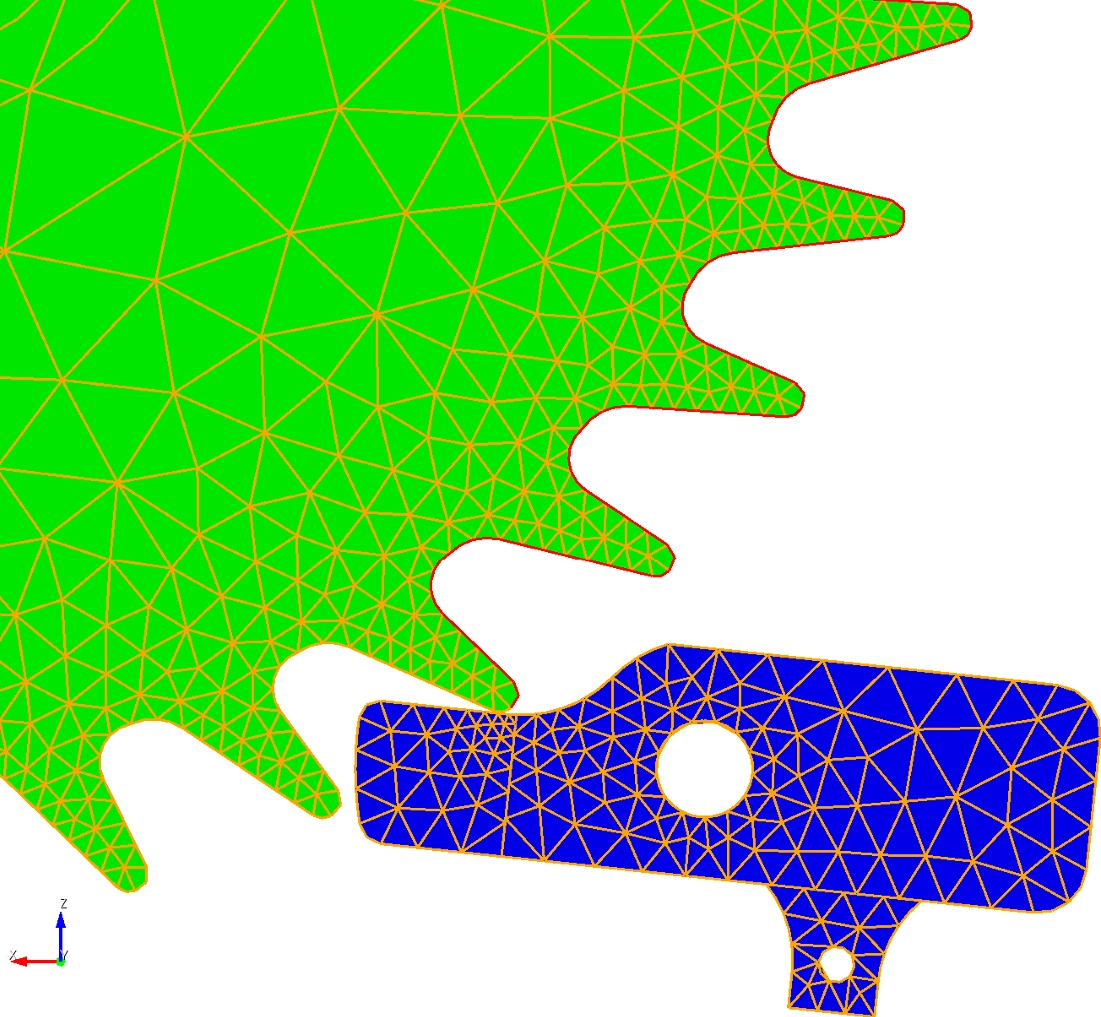
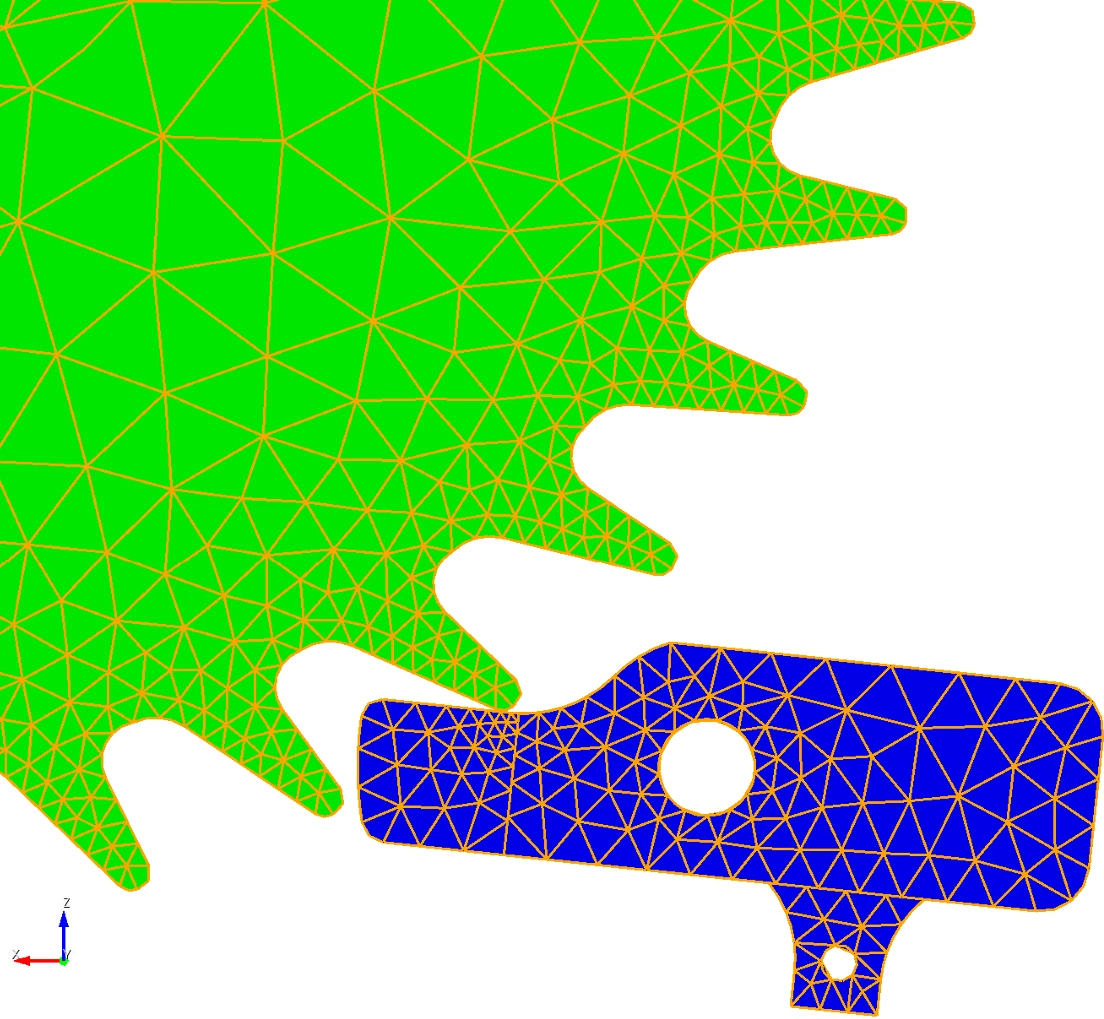
The ratchet wheel received a prescribed displacement. A pseudo-spring force seated the hold pawl against the gear, while the pawl’s support constrained its radial and axial motion and allowed rotation. Contact with the teeth determined the resulting rotation over time.
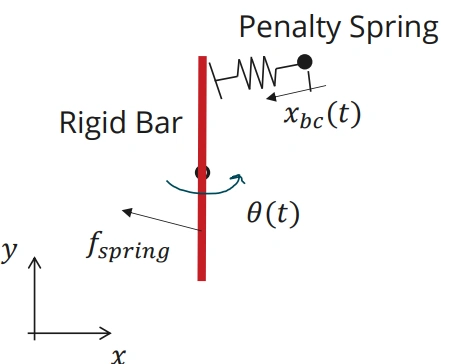
I also worked with an idealized representation using a rigid bar and a penalty spring. This provided a simpler way to examine rotation and contact alongside the finite-element response.
Shock and vibration study
The finite-element simulations used Sierra/SolidMechanics. Holding the loading case fixed while changing numerical settings let me compare their effects on the same quantity: hold-pawl rotation over time.
| Parameter | Cases compared |
|---|---|
| Momentum-balance iterations | 1, 5, 10, 20, 50, 75, and 100 |
| Mesh density | Fine, nominal, coarse, and very coarse |
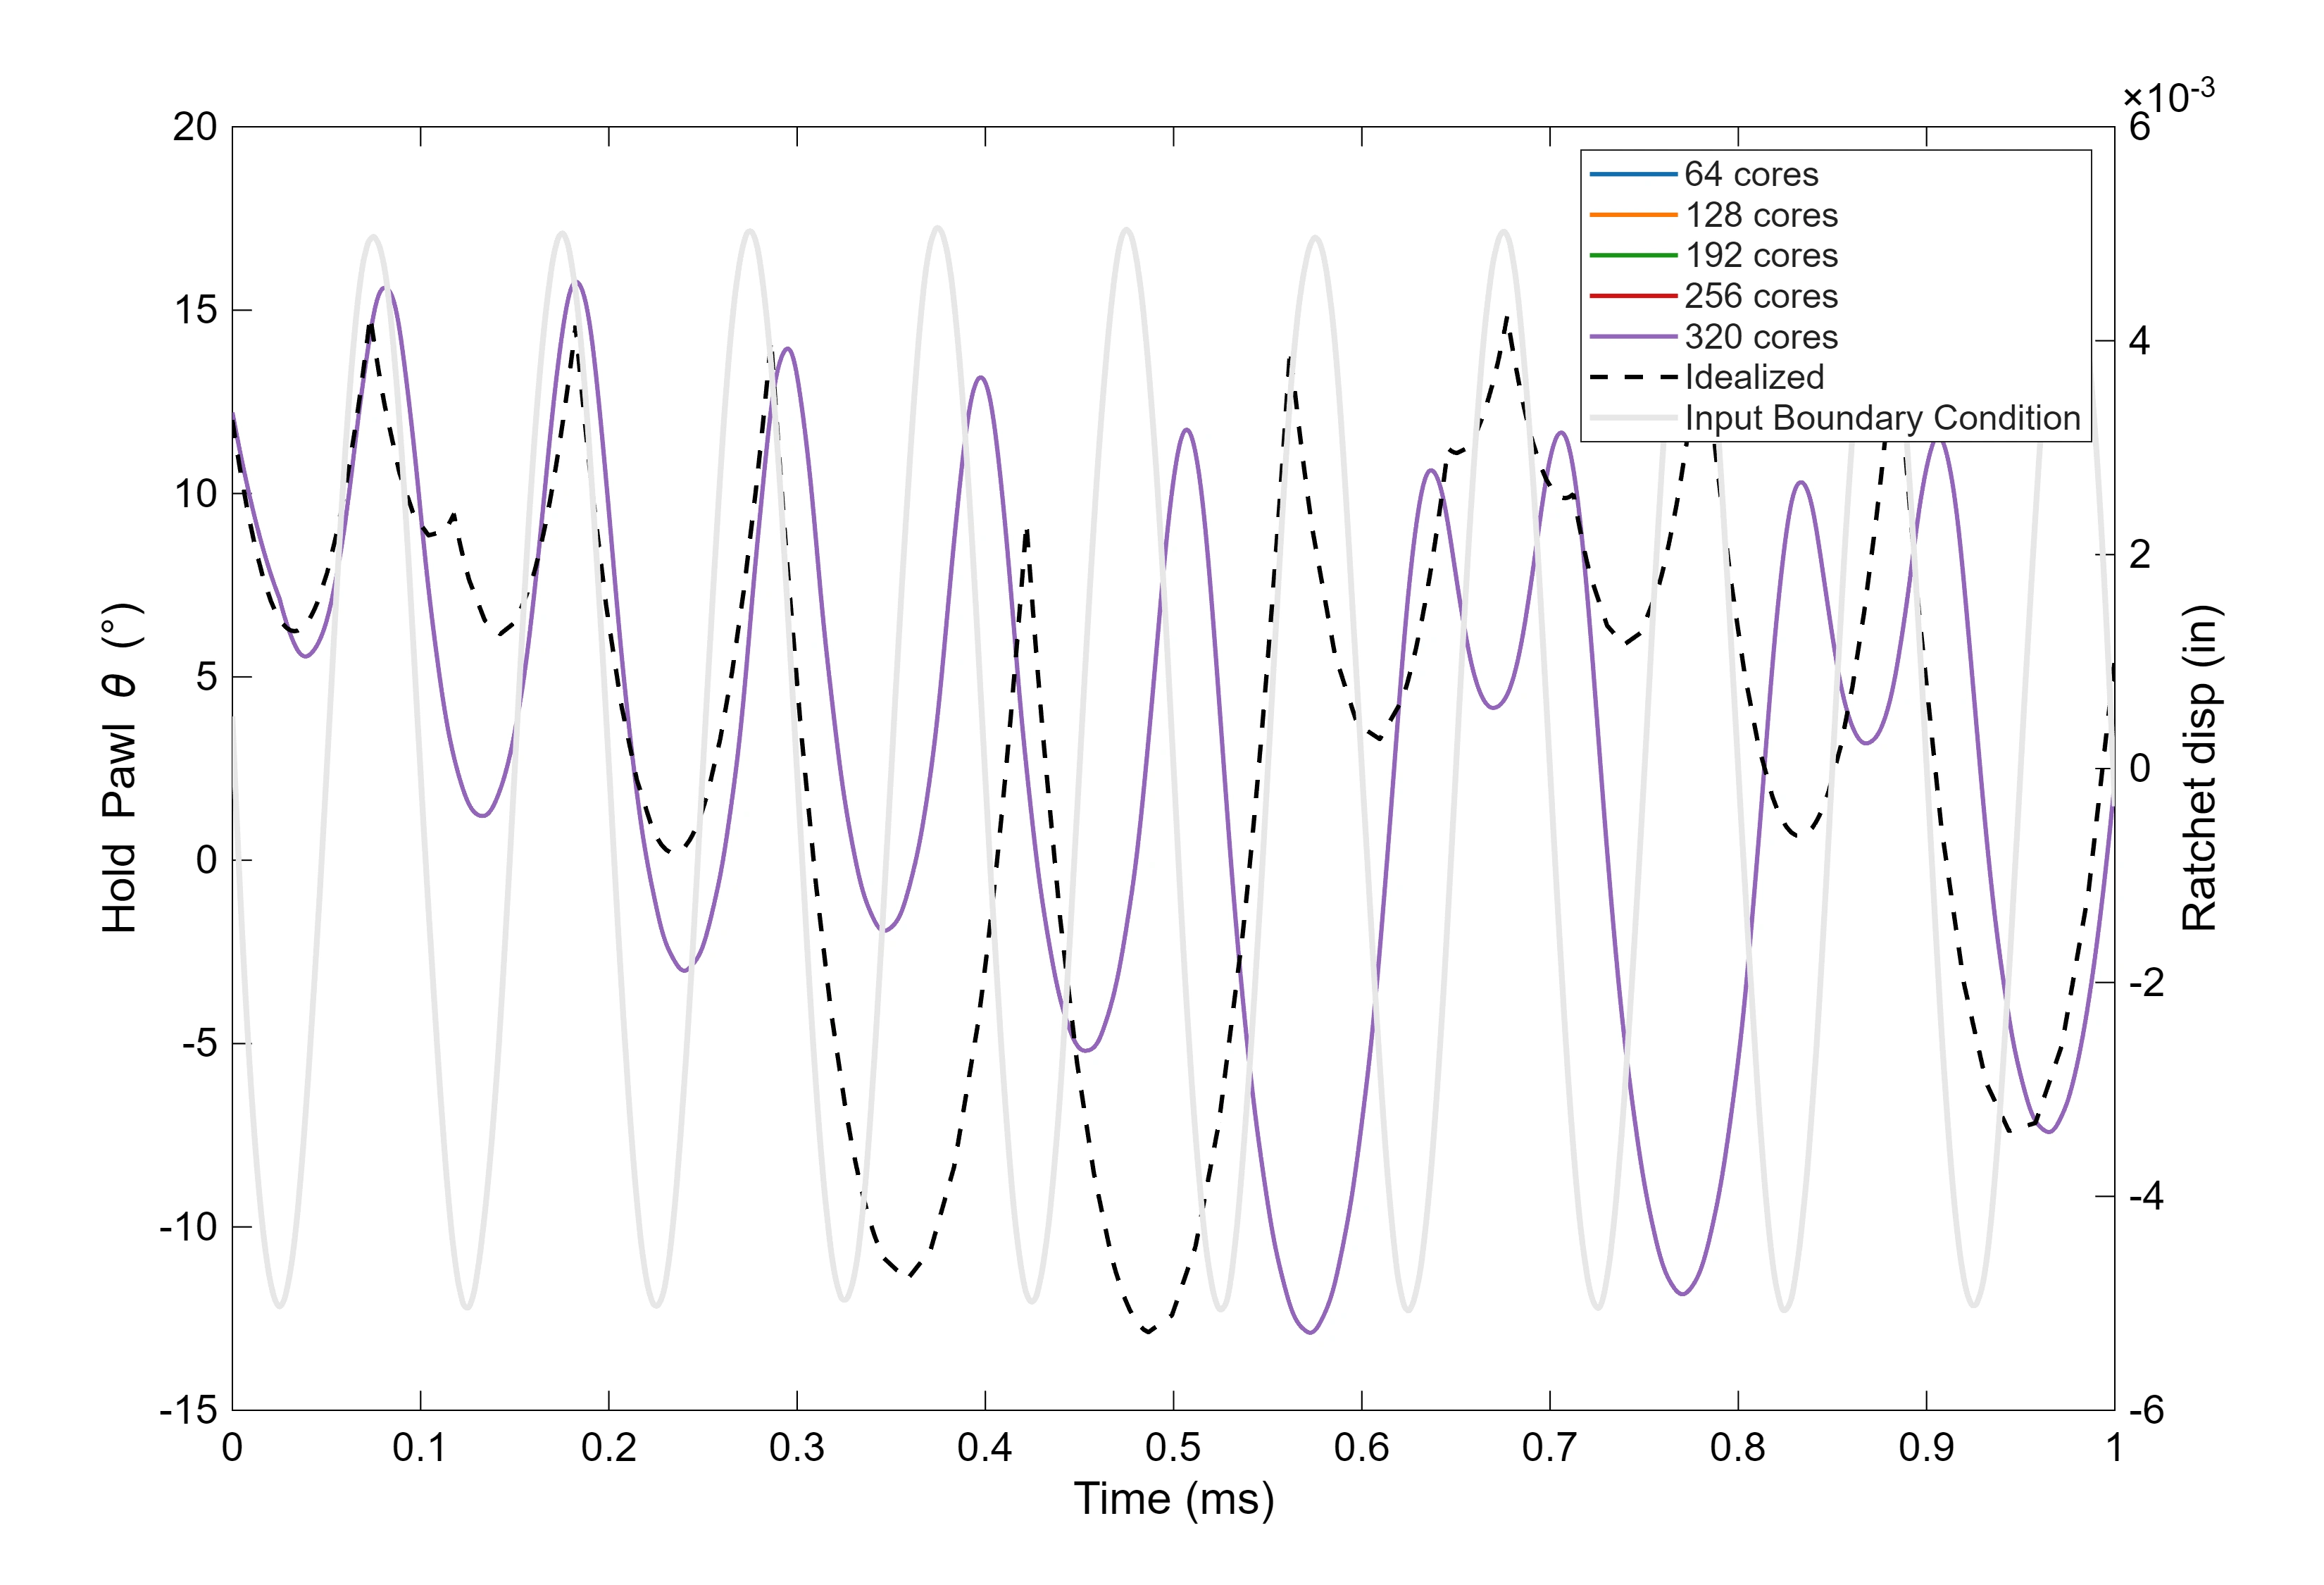
| Processor count | 64, 128, 192, 256, and 320 |
| Loading | Haversine shock and sinusoidal vibration |
What the comparisons showed
The pawl-and-gear response depended on both the numerical setting and the loading case. Under shock, several settings produced similar overall motion with differences near contact transitions. Under sustained vibration, changing iteration count or mesh density produced more pronounced differences in the rotation histories.
Iteration count
Mesh density
Processor count
In the pawl-and-gear cases studied, changing processor count gave closely overlapping rotation histories. This distinguished its response from other interactions in the larger ratcheting mechanism and helped identify which numerical choices needed closer attention.
Research team
I worked with Brennan Bahr and Shunsuke Winston on the broader NOMAD study. The team investigated three mechanism submodels: pin–spring–pawl, pin–pawl, and pawl–gear. The work shown above focuses on my primary pawl-and-gear assignment.
Quantifying the Effect of Non-Physical Parameters on the Nonlinear Dynamics of an Electromechanical Ratcheting Mechanism.
Brennan Bahr, Alan Pham, and Shunsuke Winston. Sandia NOMAD presentation, August 2025. SAND2025-09714PE.
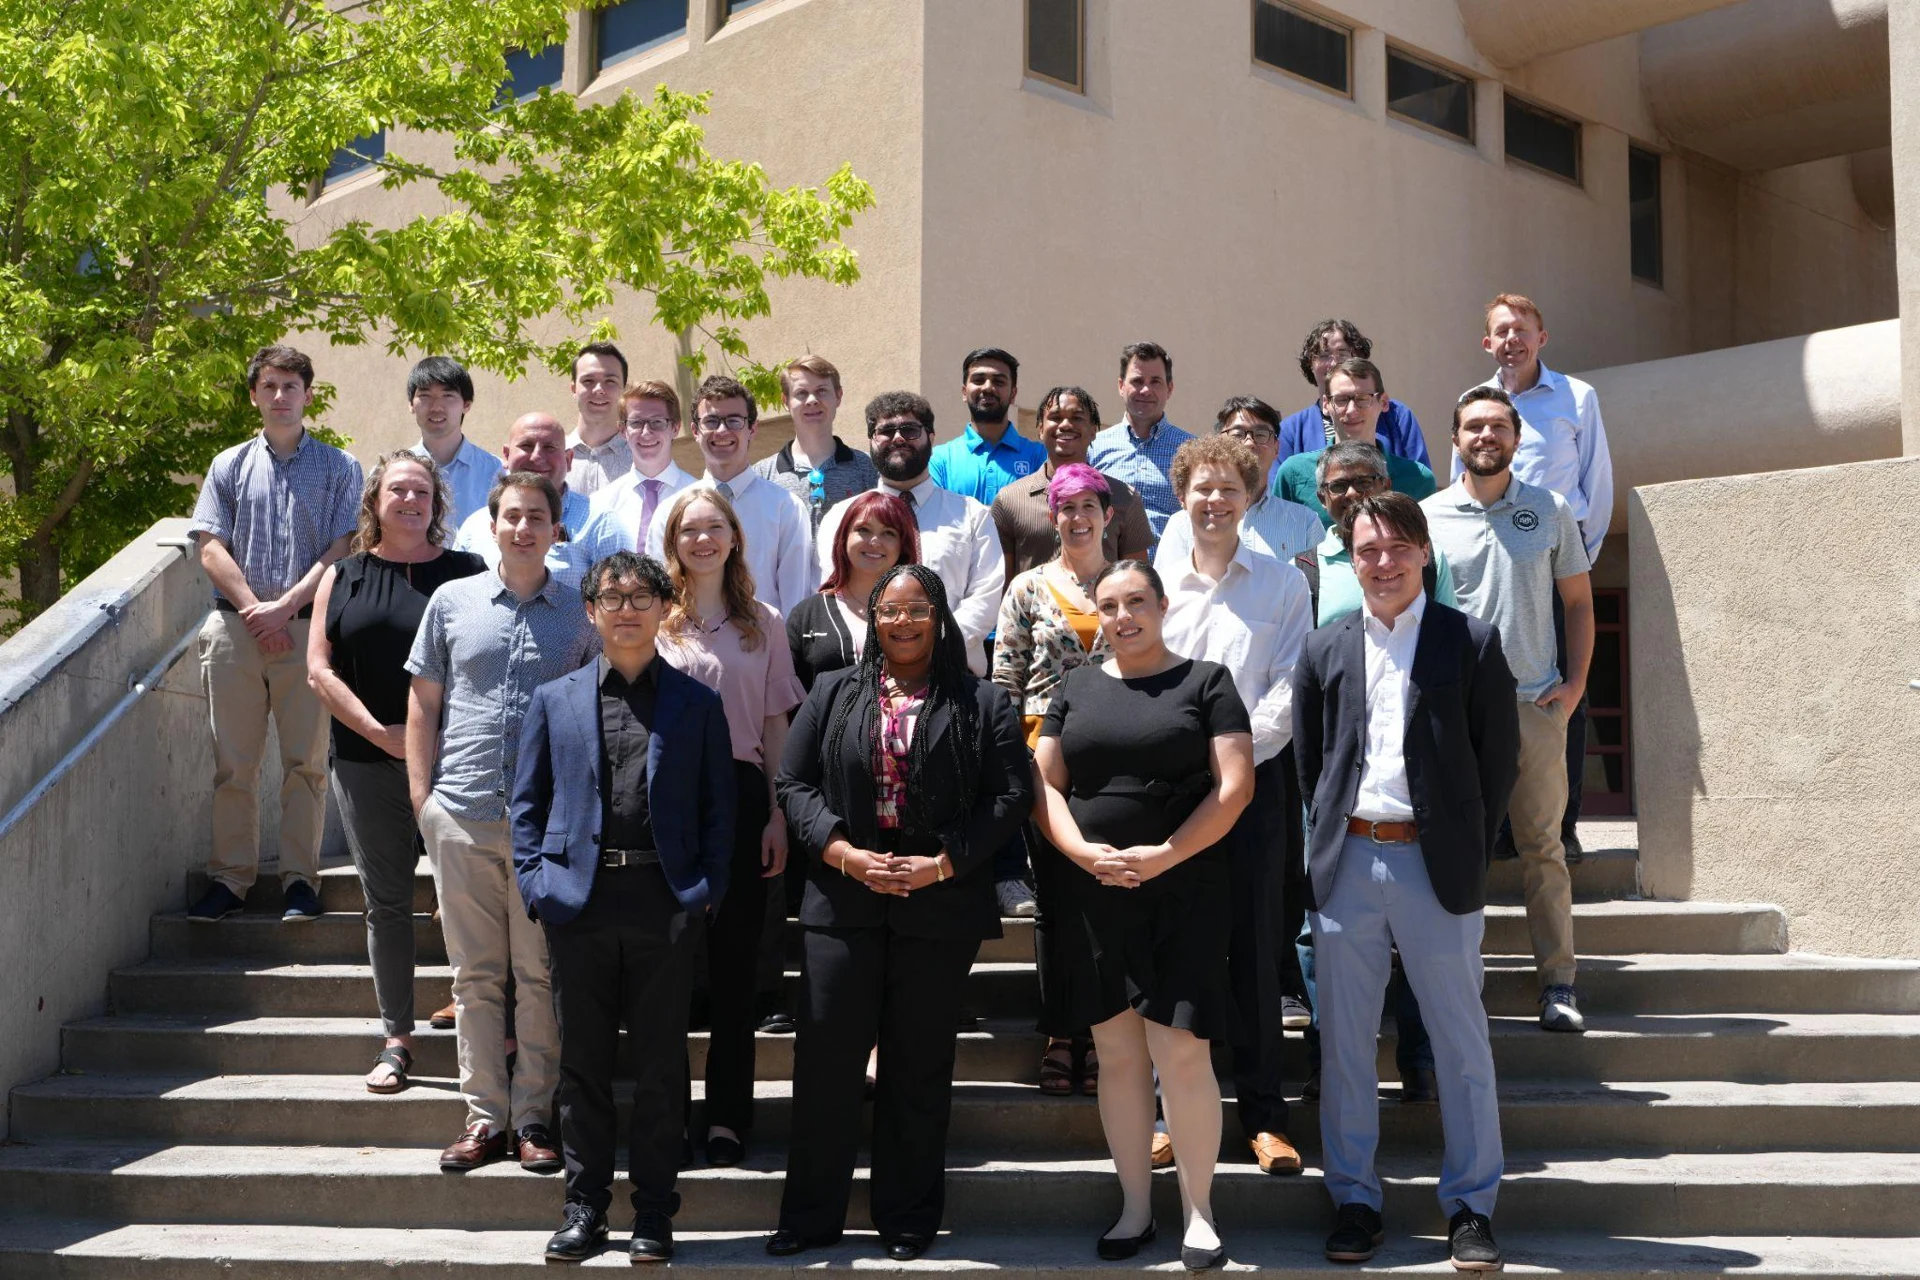
Mentors: Rob Flicek, Scott Grutzik, Rob Kuether, Chris Schumann, Aabhas Singh, and Kumar Vemaganti.